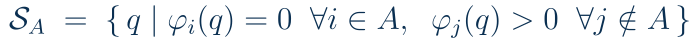Contact Modes Are Strata
What Geometric Structure Buys in Discrete–Continuous Planning
IROS 2026 Workshop on Geometric-Aware Representations in Robotics
Phone Thiha Kyaw and Jonathan Kelly
STARS Laboratory, University of Toronto Institute for Aerospace Studies
02
One Planner, Two Tasks
Two contact-rich tasks, one planner, and no modes given in advance.
a Franka FR3 pushes a T-shaped block around obstacles
a LEAP hand turns a cube toward a 120° goal
Neither plan receives a mode, a contact sequence, or a manifold. Each one is a
walk over strata of the configuration space, and every contact it makes and breaks follows from their geometry.
03
What Planners Are Given
Contact-rich manipulation couples a discrete choice, which contacts hold, with continuous motion.
Frameworks such as these take the discrete part as input.
Framework
Needs as input
Graph of Convex SetsMarcucci et al. 2024
a convex decomposition
Logic-Geometric ProgrammingToussaint 2015
a symbolic domain
Multi-Modal Motion PlanningHauser & Latombe 2010
a mode family
Planning on Sequenced ManifoldsEnglert et al. 2020
the manifold sequence itself
This work
signed distances and gradients, from a collision engine
4 fingertips, each on or off the cube, give 24 = 16 contact modes
| pairs that could touch | contact modes |
|---|
| 4 fingertips | 16 |
| 10 | 1,024 |
| 240 the hand | 2240 ≈ 1072 |
Most of these modes are infeasible, since many contacts cannot occur simultaneously, and finding the feasible ones is itself a planning problem.
04
The Coupling
Every contact the robot holds removes one dimension from its motion.
A configuration space glued together from manifolds of different dimensions is a
stratified space, and those manifolds are its strata. The idea entered robotics
through legged locomotion and finger gaiting [Goodwine & Burdick 2002]
and was set aside as impractical [Bretl et al. 2005]. Constraint
projection and fast collision engines have matured since.
05
Strata from Signed Distances
Group configurations by which signed distances vanish.
Each group is a manifold with its own dimension.
When the active gradients are linearly independent, the regular value theorem makes
each stratum an embedded submanifold. A collision engine provides
φi and ∇φi,
and the construction needs nothing more.
06
Contact Modes Are Strata
A contact mode is a stratum. A plan is a walk over strata,
following a geodesic within each one.
Strata meet along their boundaries. Making contacts steps down the stratum
graph and breaking them steps back up. The planner never builds this graph explicitly.
07
Planning on Strata
A single-tree RRT grows over the strata.
Lower-dimensional strata have measure zero, so we project samples onto them.
Extend by make, move, break
make a new contact toward the target, if it is close enough
move along the stratum, a discrete geodesic of projected steps
break a contact to move toward the target
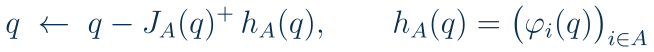
Each Newton step uses only the signed distances and their gradients.
Relabeling allows the planner to discover strata automatically, and by construction every
path in the tree is a hybrid path (a discrete sequence of strata with continuous motion within each).
08
Franka FR3 · T-shaped block around obstacles
The planner decides which face of the T to push and when to switch.
We do not provide any contact sequence.
the plan in the video · 8 makes, 7 breaks
contacts 0
stratum dimension n − # of contacts 10
The fastest trial takes 77 ms. The geometry of a ten-dimensional contact problem is
cheap enough that the discrete choice needs no search of its own.
09
LEAP Hand · in-hand cube reorientation
One grasp cannot turn the cube by 120°.
The walk becomes a gait.
the plan in the video · 46 makes, 47 breaks · ends at 116°, inside the goal tolerance
contacts 4
stratum dimension n − # of contacts 15
52 / 52
median make / break
The fingers reach their joint limits, so the plan lifts and re-places fingertips to keep
turning. We never specified this gait.
10
Open Problems
A contact mode is a stratum, but a stratum is a
richer object than a mode label.
1
Optimal walks
We return the first feasible hybrid path. Optimality over walks is open.
2
Forces, not only kinematics
The cone and the contact count approximate quasi-static pushing. Neither checks that an
admissible contact wrench can carry the motion.
3
Labeling strata
We label a stratum by the contacts that hold, but one label can stand for a
possibly disconnected union of strata, and what that costs the planner is still unclear.
Contact modes are strata.
A plan is a walk over them.
The discrete structure comes from signed distances that a collision engine already
provides. We do not provide the planner with any mode, contact sequence, or stratum, and a gait emerges on its own.
Phone Thiha Kyaw and Jonathan Kelly
phone.thiha@robotics.utias.utoronto.ca