Open source
Software
A selection of open-source projects I’ve authored or contributed to — mostly motion planning, robotics software, and research code. Most live in my GitHub or in collaborator orgs.
Featured
Built on geodex
geodex_nav2_planner
A Nav2 global planner on SE(2). It plans with G-RRT* under a metric that weights forward, sideways and turning motion, checks the full footprint polygon against the costmap, and smooths the path with geodex's metric-aware smoother.
geodex_moveit
A MoveIt 2 planner plugin for fixed-base arms. It plans joint-space paths with G-RRT* under a Euclidean or a kinetic-energy metric, and smooths them with geodex's metric-aware smoother.
More projects
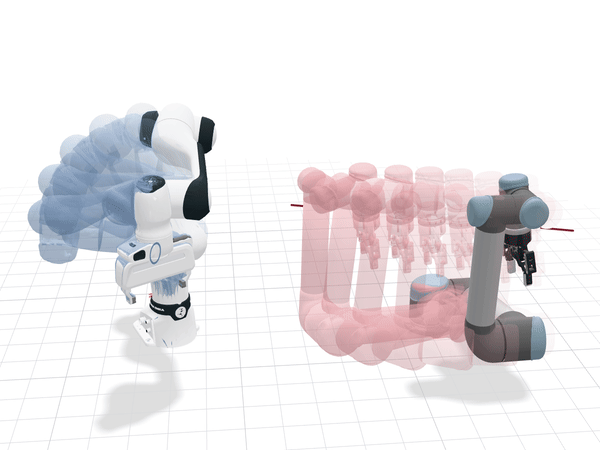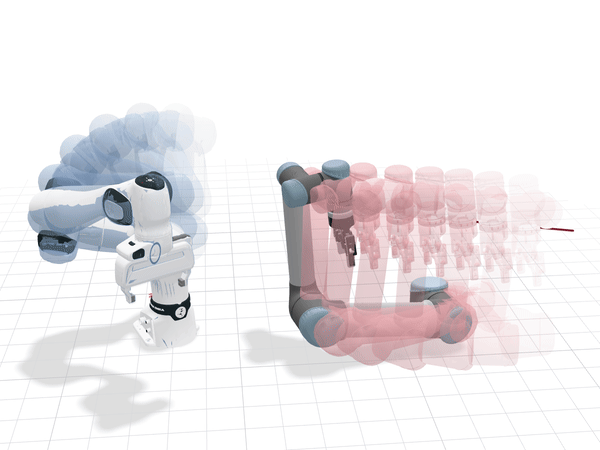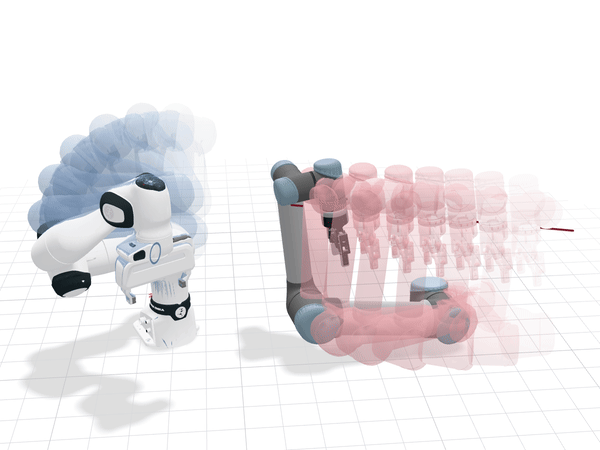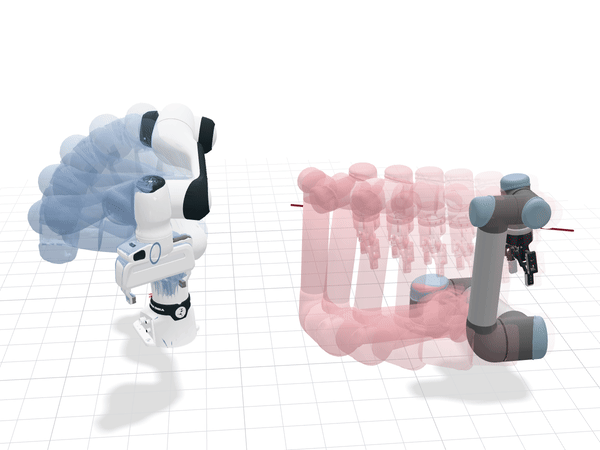
ConstraintIK
Code and models for our CoRL 2026 paper on the intrinsic geometry of diffusion models with constrained inverse kinematics. We train one conditional diffusion model across seven constraint families for the UR5 and the Franka.
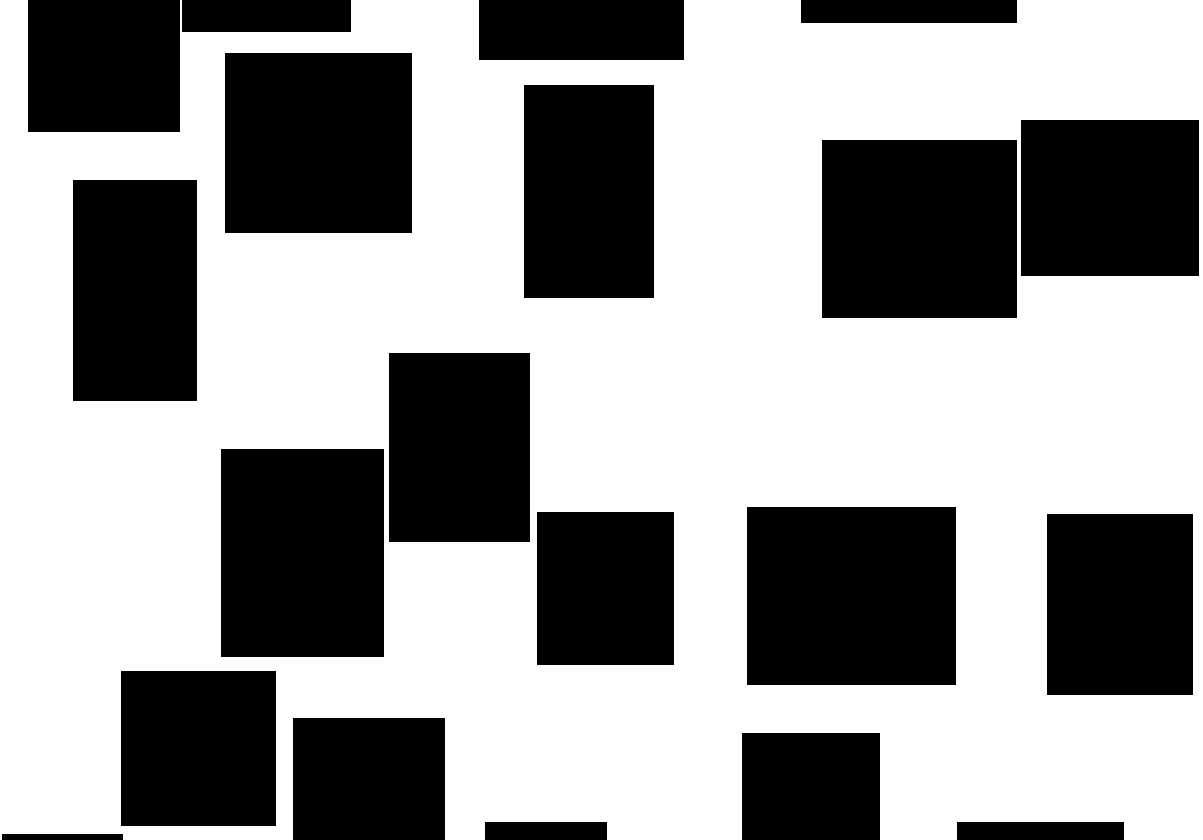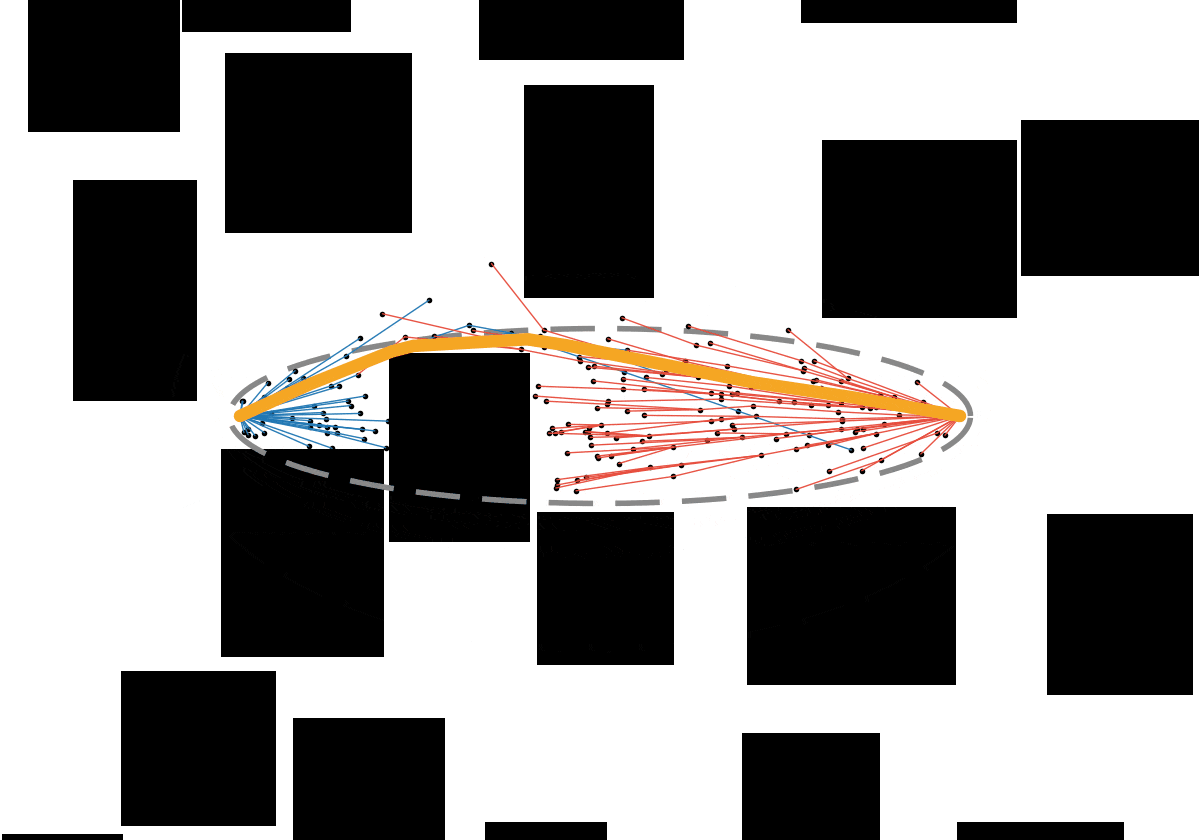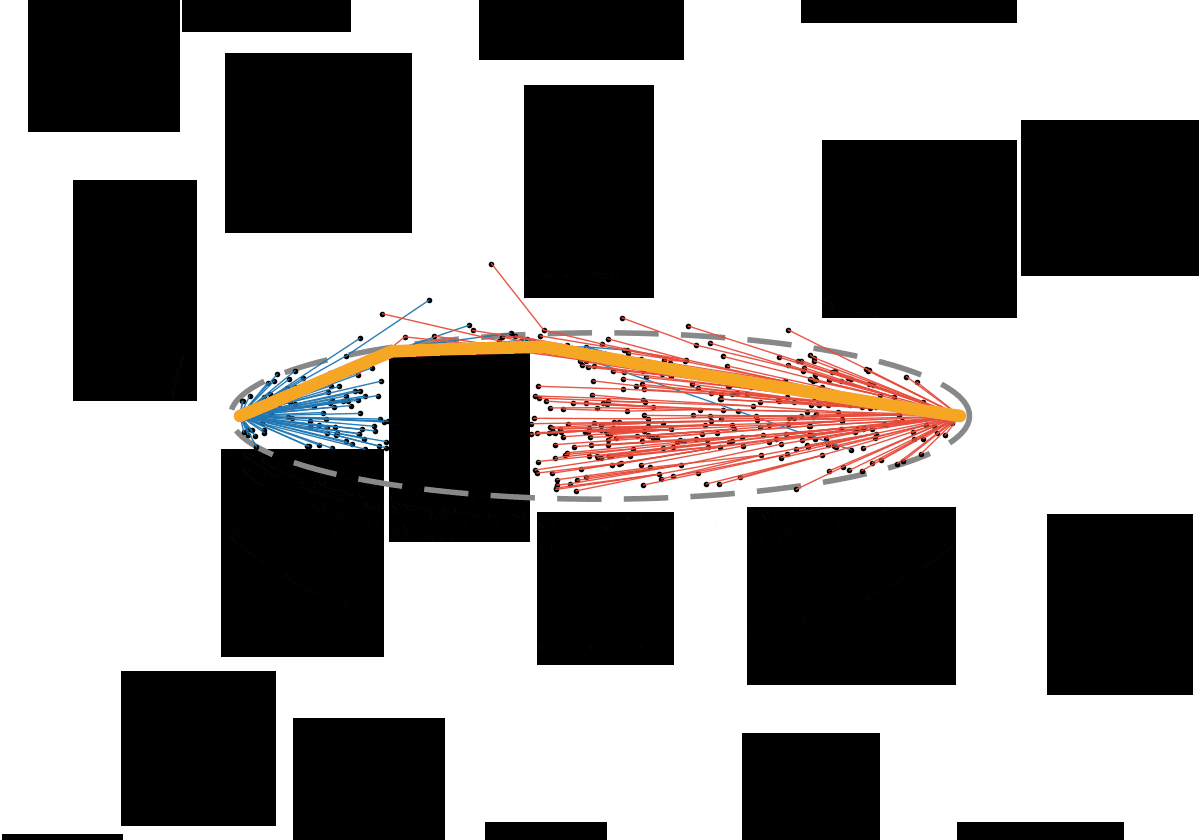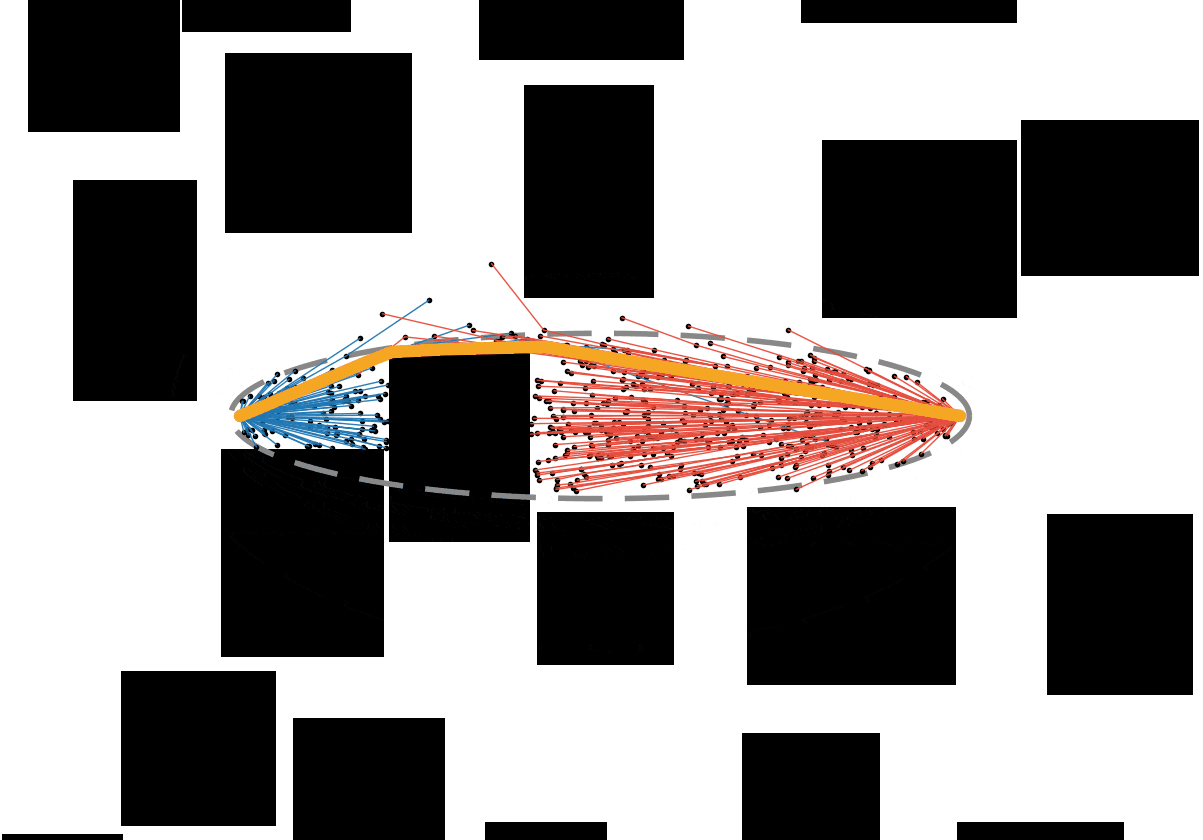
Greedy RRT*
A bidirectional, asymptotically optimal sampling-based motion planner. Contributed to OMPL (Open Motion Planning Library) and VAMP (Vector-Accelerated Motion Planning) as part of my MASc/PhD research at STARS Lab.